 CNY



Product Overview
SO-ARM101 is an open-source robotic arm deeply optimized from SO-ARM100. Revised cable routing and motor/gear pairings eliminate the joint cable-breakage problem, and the performance upgrades support real-time leader-follower following. This is the 7-DOF version: it adds a wrist roll (yaw) servo over the 6-axis model, giving the wrist far greater freedom of posture, more reachable points and multi-angle precision grasping. It adapts perfectly to the Hugging Face LeRobot toolkit and connects directly to PyTorch models and shared datasets, so imitation learning and reinforcement learning are easy to put into practice. A complete assembly tutorial and DIY kit are included — students, researchers and makers can all work with intelligent robotics for learning, research and creation.

What is Hugging Face LeRobot? LeRobot is the open-source robotics ecosystem from the world-renowned AI community Hugging Face. It combines a Python library with a model-sharing platform, packaging standardized tools, datasets and pretrained models so that frontier AI techniques such as imitation learning and reinforcement learning are within reach — developers, students and hobbyists can all get hands-on with robotics development.
What can it do? Assembly is simple and requires no complex debugging. Using the leader-follower structure, the leader arm performs a grasp or placement and the follower arm mirrors it in real time; a small amount of training is enough for it to complete preset tasks independently. It connects directly to shared AI models and datasets with no need to write code from scratch, making it suitable for grasping and light assembly experiments. Low cost and low barrier make it an efficient route into embodied AI practice for students, researchers and makers.
Ships factory assembled via SF Express with free shipping. Invoices are available, and a KVM switch is included as a gift with finished-unit packages.
At a glance: 7DOF with 90° wrist roll · 12V high-torque servos at 30kg.cm · optional TPU flexible gripper · dual-view data collection · NVIDIA and D-Robotics RDK onboard inference · factory assembled and ready to use · supports ACT / SmolVLA / Pi0 / Pi0.5 / GR00T N1.5 model training.
High-precision magnetic encoding · End-to-end imitation learning · Hugging Face LeRobot · Teleoperation collaboration algorithms · Precise data collection · ACT model training · Arm-mounted camera vision · Scene camera perspective · Precise positioning with real-time feedback · 7DOF (7 degrees of freedom) · Leader-follower structure · 30KG high-torque bus servos · HD wide-angle camera · Supports secondary development · Textbook-grade tutorials.
Key Advantages
-
7 Degrees of Freedom with 90° Wrist Roll
The 7-DOF version adds a left/right wrist roll (yaw) servo to the 6-axis design, so the wrist can approach a target from far more angles and reach more points in the workspace. That extra freedom is what makes multi-angle, fine-grained grasping possible.
-
Leader-Follower Teleoperation & Imitation Learning
The arm integrates the Hugging Face AI framework. Teleoperate the leader arm to record demonstration motions, then train an imitation learning model in one pass and deploy the optimized policy. It can take on complex tasks and adapt to its environment, closing the automation loop end to end.
-
Dual-View Global Coverage
The SO-ARM101 arm-mounted camera captures the target's spatial position, angle and surface texture at close range for higher-fidelity data collection, while a desk-stand scene camera reads the workspace environment in real time. Together they keep operation precise, respond quickly to changes and prevent drift or stalling.
-
30kg.cm High-Torque 12V Bus Servos
The follower arm is unified at 7 × Feetech STS3215-C018 (12V, 30kg.cm, 1:345) to guarantee sufficient grasping torque under multi-axis load, while the leader arm stays at 7.4V to balance hand feel against cost. A 12-bit magnetic encoder delivers 0.088° precision on every axis.
-
Multi-Model Training Support
Train and deploy ACT, SmolVLA, Pi0, Pi0.5 and GR00T N1.5 policies on the same hardware, and reuse pretrained models such as lerobot/smolvla_base, lerobot/pi0_base, lerobot/pi05_base and lerobot/xvla-widowx directly from the LeRobot model hub.
-
Onboard Inference on NVIDIA and D-Robotics RDK
Connect a single cable to a Raspberry Pi, D-Robotics RDK or NVIDIA Jetson controller to run inference on the arm itself, with real-time motor control and encoder feedback.
-
Factory Assembled, Ready to Use Out of the Box
Every unit ships assembled, wired and calibrated — connect power and USB and the platform is ready for teleoperation and data collection.
Upgradeable Flexible Gripper
The flexible gripper is an upgrade of the standard rigid gripper, 3D printed in a flexible TPU material. It uses a hollow design with internal reinforcing ribs and works on a fin-type gripper principle: it conforms to the shape of the object being grasped, reducing the contact force applied to it. That makes the gripper ideal for complex shapes or objects with fragile components — fruit, for example — because it lowers the control precision needed to handle them safely.
How it works: on contact, the top and bottom of the fin-shaped jaws bend toward the object, so the gripper wraps around its surface. That increases the load-bearing contact area and produces a firm hold.
-
Ideal for: soft or easily damaged items that cannot be handled by a conventional rigid gripper — fruit, glassware, eggs and food processing.
-
Adaptive to shape: cylinders, spheres, ellipses and polygons — the full family of circle-based object shapes.
Hardware Overview
Available Versions:
The 7-axis version no longer splits into "Standard" and "Pro" variants, because the follower arm is unified at 12V. Versions now differ only by the leader arm's damping, while the follower arm is always STS3215-C018.
|
Configuration |
Servo Layout |
|
Leader Arm (Damped) |
1 × STS3215-C001 (7.4V, 1:345) + 2 × STS3215-C044 (7.4V, 1:191) + 3 × STS3215-C046 (7.4V, 1:147) |
|
Leader Arm (Zero-Damping) |
7 × STS3215-C066 (7.4V, no gear ratio) — dummy unpowered servos optional |
|
Follower Arm (All Versions) |
7 × STS3215-C018 (12V, 1:345) — unified, no 7.4V variant |
|
Power Adapter |
Leader arm 5V6A / Follower arm 12V5A |
Leader arm total: 7 × STS3215 (7.4V) across the seven axes. Follower arm total: 7 × STS3215-C018 (12V, 30kg.cm).
Available Packages:
|
Package |
Finished Unit (PLA Gripper) |
Finished Unit (TPU Gripper) |
Arm-Mounted Camera Kit |
Dual-Camera Kit |
|
Positioning |
Standard entry point |
Flexible-gripper ready |
First choice for data collection |
Two-star embodied inference setup |
|
Printed Parts |
Leader + follower arm |
Leader + follower arm |
Leader + follower arm |
Leader + follower arm |
|
Leader Arm Servos |
7 × Feetech STS3215 (7.4V); dummy unpowered servos optional |
7 × Feetech STS3215 (7.4V); dummy unpowered servos optional |
7 × Feetech STS3215 (7.4V); dummy unpowered servos optional |
7 × Feetech STS3215 (7.4V); dummy unpowered servos optional |
|
Follower Arm Servos |
7 × Feetech STS3215-C018 (12V) |
7 × Feetech STS3215-C018 (12V) |
7 × Feetech STS3215-C018 (12V) |
7 × Feetech STS3215-C018 (12V) |
|
Servo Driver Board |
✓ |
✓ |
✓ |
✓ |
|
Power Adapters |
✓ |
✓ |
✓ |
✓ |
|
Data Cable / Desk Clamp / USB 3.0 Hub |
✓ |
✓ |
✓ |
✓ |
|
Flexible Gripper |
PLA rigid gripper |
TPU flexible gripper |
Optional TPU |
Optional TPU |
|
Arm-Mounted Vision |
— |
— |
Auto-focus 30FPS or fixed-focus 60FPS camera |
Auto-focus 30FPS / fixed-focus 60FPS × 2 |
|
Scene (Side) View |
— |
— |
— |
✓ (scene camera) |
|
Dual-View Data Collection |
— |
— |
— |
✓ |
Our recommendation: the fixed-focus 60FPS camera, TPU gripper, dummy unpowered servos and the dual-camera kit. Together these give you the dual-view data collection setup: 60FPS fixed-focus for smooth high-frame-rate capture, TPU to grip irregular objects, and dummy servos to lower the price of entry while still enjoying the full version.
Hardware Highlights:
The exploded hardware view shows the top accessories — optional auto-focus 30FPS / fixed-focus 60FPS camera, Feetech STS3215 servos and the optional TPU flexible gripper; the main assembly — desk stand, SO-ARM101 leader arm (7 DOF) and SO-ARM101 follower arm (7 DOF); and the base accessories — Bambu PLA+ printed parts, servo driver board and Feetech STS3215 servos.
Compatible Devices:
Raspberry Pi / D-Robotics RDK / NVIDIA Jetson series controllers, plus Windows and Linux host PCs over USB serial. Fully compatible with the LeRobot SO-ARM101 open-source project and most serial bus servos on the market; the dual follower arm packages are designed for XLeRobot.
3-Step Easy Setup:
-
Unpack both arms. They arrive assembled, wired and calibrated, so no mechanical assembly or servo ID configuration is required.
-
Fit the optional accessories: the arm-mounted camera bracket and the flexible gripper. Both attach with the supplied hardware and need no modification.
-
Connect the servo driver board to your Raspberry Pi, RDK or Jetson controller, power the leader arm (5V6A) and follower arm (12V5A), and follow the LeRobot tutorials to teleoperate, collect data and train.
Technical Specifications
Servo Layout (7-DOF, Follower Arm View, Servos Numbered 1–7)
|
Arm |
Servo Configuration |
|
Follower Arm |
7 × STS3215-C018 (12V, 1:345) |
|
Leader Arm |
STS3215-C001 (1:345) + STS3215-C044 (1:191) + STS3215-C046 (1:147), all 7.4V |
|
Added Over 6-Axis |
Wrist roll (left/right yaw) axis plus wrist pitch axis — 7 servos in total |
STS3215 Bus Servo (Both Models Used by the 7-Axis Arm)
|
Parameter |
STS3215-C018 |
STS3215-C001 |
|
Rotation Speed |
0.222sec/60° (45RPM) @12V |
0.192sec/60° (52RPM) @7.4V |
|
Stall Torque |
30kg.cm @12V |
19.5kg.cm @7.4V |
|
Servo Precision |
0.088° |
0.088° |
|
Protection |
Voltage / stall / over-temperature protection |
Voltage / stall / over-temperature protection |
|
Data Readback |
Supported — angle, temperature, voltage, position |
Supported — angle, temperature, voltage, position |
|
Used In |
Follower arm × 7 |
Leader arm (damped joints) |
The STS3215 integrates two high-quality magnetic encoder motors with a 12-bit high-precision magnetic encoding angle sensor, 360° controllability, data readback and multiple operating modes for millisecond-level coordinated response. On the 7-axis version the follower arm uses only C018 (30kg.cm @12V) so that grasping torque stays sufficient under multi-axis load, while the leader arm remains at 7.4V to balance hand feel against cost.
Camera Module Options
|
Parameter |
Auto-Focus (Zoom) 30FPS |
Fixed-Focus 60FPS |
|
Pixels |
2MP |
2MP |
|
Image Sensor |
OV2720 (1/5.8") |
GC2093 |
|
Field of View / Focal Length |
86° distortion-free / 1.8mm |
100° / fixed focus (default 60cm) |
|
Output |
USB 2.0 |
USB 2.0 |
|
Format |
MJPG / YUY2 |
MJPG / YUY2 |
|
MJPG (Resolution / Frame Rate) |
640x480 30FPS / 800x600 30FPS / 1280x720 30FPS / 1280x800 30FPS / 1280x1024 30FPS / 1920x1080 30FPS |
640x480 60FPS / 800x600 60FPS / 1280x720 60FPS / 1920x1080 60FPS |
|
YUY2 (Resolution / Frame Rate) |
640x480 30FPS / 800x600 10FPS / 1280x720 10FPS / 1280x800 10FPS / 1280x1024 5FPS / 1920x1080 5FPS |
640x480 30FPS / 800x600 20FPS / 1280x720 10FPS / 1920x1080 5FPS |
|
Features |
Standard UVC protocol, driver-free |
Standard UVC protocol, driver-free |
Auto-Focus Camera Modes
Auto-focus / manual focus switchable · 1080P@30FPS · 86° distortion-free. In auto-focus mode, when mounted on the arm's gripper, the camera tracks moving targets in real time and requires no manual focal adjustment, keeping the image sharp during dynamic tasks such as grasping and detection. In manual focus mode the focal distance is locked, so capture stays stable when the camera is fixed in position.
Camera Mount Kit
Carries a 1080P HD 2MP camera module, available as either an 86° auto-focus 30FPS camera or a 100° wide-angle fixed-focus 60FPS camera. USB driver-free and plug-and-play for high-precision image capture and processing. Choose from arm-mounted, side-view or top-view camera mount kits to cover most application scenarios.
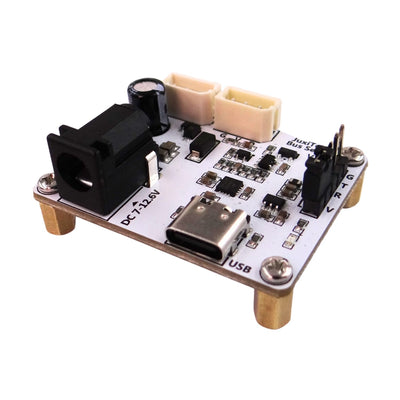
Servo Driver Board (JUXI Bus Servo Adapter)
|
Power Input — 5~12V |
Power Connector — DC5521 |
|
Servo Interface — TTL bus servo interface |
Communication Interface — USB Type-C & UART |
|
Mounting Hole Spacing — 37.00 x 28.00mm |
Mounting Hole Diameter — 2.5mm |
|
Product Dimensions — 42.00 x 33.00mm |
Product Weight — 15g |
The serial bus servo driver board has a clean plug-and-play design and includes a TVS voltage-regulation protection module to prevent high-voltage breakdown. A single cable connects it to Raspberry Pi, D-Robotics RDK or NVIDIA Jetson controllers for real-time motor control and encoder data feedback. Board interfaces: TTL bus servo interface, TVS protection circuit, DC5521 power input, UART communication interface, LED indicator and USB Type-C. It supports the LeRobot SO-ARM101 7-DOF robotic arm and most serial bus servos on the market.
Product Specifications
|
Product Name |
SO-ARM101 (7 degrees of freedom) |
|
Product Material |
Bambu PLA+ |
|
Degrees of Freedom |
7 DOF (including the new wrist roll axis) |
|
Product Dimensions |
Leader arm 111 x 239 x 525mm / Follower arm 111 x 173 x 532mm 6-axis reference figures — 7-axis dimensions follow the final measured drawings |
|
Product Weight |
Leader arm approx. 680g / Follower arm approx. 690g 6-axis reference figures — 7-axis weights follow the final measured values |
|
Gripper Material |
PLA, optional TPU |
|
Servo Driver Board |
JUXI Bus Servo Adapter |
|
Servo Count |
Follower arm 7 × STS3215-C018 (12V) / Leader arm 7 × STS3215 (7.4V) |
|
Servo Torque |
Follower arm 30kg.cm @12V (high torque) |
|
Camera |
2MP 1080P HD camera module (optional fixed-focus 60FPS / auto-focus 30FPS) |
|
Power Supply |
DC5521 5V6A (leader arm) / DC5521 12V5A (follower arm) |
|
Operating System |
Windows / Linux |
|
Control Interface |
USB serial communication |
|
Programming Language |
Python |
7-axis dimensions and weights must be updated from the actual 7-servo assembly. The figures above are 6-axis reference values — please refer to the final annotated drawings for the 7-axis version.


Applications
-
University research — teaching labs and research projects in robotics, artificial intelligence and automation.
-
Developers and makers — algorithm development, prototype validation and robotics competitions.
-
Educational institutions — an ideal teaching aid for advanced courses in AI programming.
-
Enthusiasts — DIY a desktop robot that puts real AI techniques into practice.
Hugging Face Ecosystem & Open Source
The SO-ARM101 7-DOF arm connects seamlessly to the Hugging Face community. It can directly reuse the pretrained models, datasets and algorithm libraries provided by the LeRobot project, and supports collaborative sharing of code and experience with developers worldwide — lowering the technical barrier to research and giving users an entry point into embodied AI.
Hugging Face LeRobot Model Hub
Pretrained policies are ready to reuse straight from the hub, including lerobot/smolvla_base, lerobot/pi0_base, lerobot/pi05_base and lerobot/xvla-widowx — around 18 models in total.
Open Source
This product is based on the LeRobot SO-ARM101 open-source project: github.com/huggingface/lerobot. It complies with the Apache License 2.0 and is fully compatible with the LeRobot ecosystem, so users can integrate it directly — lowering the development barrier and speeding up project delivery.
Technical Support
A complete, step-by-step replication tutorial covers the full workflow, so even users with no programming background can reproduce and deploy the platform without barriers. Search for "JuxiTechnology" on GitHub or Gitee to view the materials, or contact our support team if you run into any issues.
-
Full assembly, wiring and calibration reference for the 7-DOF arms.
-
Leader-follower teleoperation setup and servo ID configuration.
-
Arm-mounted and scene camera setup with LeRobot dataset collection.
-
Imitation learning training and deployment walkthroughs (ACT, SmolVLA, Pi0, Pi0.5, GR00T N1.5).
For detailed technical documentation on software setup and code implementation, please refer to our official Wiki: Access Here. Community technical support is also available to help you accelerate project implementation.
Gifts & Bundled Accessories
Rubber Gripper Anti-Slip Pad (Included)
The anti-slip pad is supplied as a single sheet that you cut into pieces to fit the gripper jaws. Cutting it to shape yourself avoids the pad peeling off over time.
KVM Switch (Included with Finished Units)
Works with both Windows and Linux computers and switches between two devices. Features hardware-level full-scenario compatibility, USB 2.0 high-speed low-latency transfer with ample bandwidth, UART + TTL serial ports, high-sensitivity infrared remote switching, and seamless cross-device switching with a real-time visible connection status.
Note: the KVM switch is not included with non-finished-unit (kit) packages.
Part List
Finished Unit · PLA Gripper:
-
Follower arm (12V) — 7 × STS3215-C018 servos
-
Leader arm (7.4V) — 7 × STS3215 servos, damped or zero-damping optional
-
PLA rigid gripper × 1
-
5V6A power adapter × 1 | 12V5A power adapter × 1
-
Servo driver board × 2 | Type-C data cable × 2 | USB 3.0 hub × 1
-
G-type fixing clamp × 4 | Phillips screwdriver × 1
Finished Unit · TPU Gripper:
Same as the Finished Unit · PLA Gripper, with the gripper replaced by a TPU flexible gripper.
Arm-Mounted Camera Kit · PLA Gripper:
-
Follower arm (12V) — 7 × STS3215-C018 servos
-
Leader arm (7.4V) — 7 × STS3215 servos, damped or zero-damping optional
-
PLA rigid gripper × 1
-
SO-ARM101 arm-mounted bracket × 1 | Camera module × 1 (auto-focus 30FPS or fixed-focus 60FPS)
-
USB cable × 1 [1.5m for auto-focus / 1m for fixed-focus]
-
5V6A power adapter × 1 | 12V5A power adapter × 1
-
Servo driver board × 2 | Type-C data cable × 2 | USB 3.0 hub × 1
-
G-type fixing clamp × 4 | Phillips screwdriver × 1
Arm-Mounted Camera Kit · TPU Gripper:
Same as the Arm-Mounted Camera Kit · PLA Gripper, with the gripper replaced by a TPU flexible gripper.
Dual-Camera Kit · PLA Gripper:
-
Follower arm (12V) — 7 × STS3215-C018 servos
-
Leader arm (7.4V) — 7 × STS3215 servos, damped or zero-damping optional
-
PLA rigid gripper × 1
-
SO-ARM101 arm-mounted bracket × 1 | Camera module × 2 (auto-focus 30FPS or fixed-focus 60FPS)
-
USB cable × 2 [1.5m for auto-focus / 1m for fixed-focus]
-
5V6A power adapter × 1 | 12V5A power adapter × 1
-
Servo driver board × 2 | Type-C data cable × 2 | USB 3.0 hub × 1
-
G-type fixing clamp × 4 | Phillips screwdriver × 1
-
Desk stand × 1 | Camera fixing bracket × 1
Dual-Camera Kit · TPU Gripper:
Same as the Dual-Camera Kit · PLA Gripper, with the gripper replaced by a TPU flexible gripper.
Dual Follower Arm Finished Unit (for XLeRobot):
-
Follower arm (12V) × 2 — 7 × STS3215-C018 servos per arm
-
12V5A power adapter × 2 | Servo driver board × 2
-
Type-C data cable × 2 | USB 3.0 hub × 1
-
F-type fixing clamp × 4 | Phillips screwdriver × 1
Dual Follower Arm with Dual Arm-Mounted Cameras (for XLeRobot):
-
Follower arm (12V) × 2 — 7 × STS3215-C018 servos per arm
-
SO-ARM101 arm-mounted bracket × 2 | Camera module × 2 (auto-focus 30FPS or fixed-focus 60FPS)
-
USB cable × 2 [1.5m for auto-focus / 1m for fixed-focus]
-
12V5A power adapter × 2 | Servo driver board × 2
-
Type-C data cable × 2 | USB 3.0 hub × 1
-
G-type fixing clamp × 4 | Phillips screwdriver × 1
よくある質問
What is the SO-ARM101 Open Source 7-DOF Robotic Arm?
Where can I find technical documentation and open-source files for the SO-ARM101 Open Source 7-DOF Robotic Arm?
What platforms and frameworks is the SO-ARM101 Open Source 7-DOF Robotic Arm compatible with?
How can I get technical support for the SO-ARM101 Open Source 7-DOF Robotic Arm?
ビデオなし
他におすすめの商品

2-DOFサーボパンチルトユニット

3D RealSense 深度カメラ

4-in-1 KVM スイッチ HUB | TTL シリアル Bluetooth ドッキングステーション

4K HD HDMI キャプチャーカード


79° IMX219 CSI カメラ

ロボットナビゲーション用 AHRS 姿勢方位角センサー IMU モジュール

AI 音声認識モジュール — キーワード起動、バイリンガル音声、110+ コマンド

AmazingHand オープンソース研究用生体模倣ロボットハンド

バスサーボドライバーボード


AI 音声対話向け ドライバ不要 USB 2.0 サウンドカード(オンボードマイク内蔵)
Read technical documentation, schematics, and research papers on wiki.juxitech.com