 CNY



SO-ARM101 & AmazingHand Open Source Dexterous Hand Robotic Arm


Product Overview
The SO-ARM101 & AmazingHand is a complete open-source embodied AI platform that pairs the SO-ARM101 6-axis robotic arm with the AmazingHand 8-DOF four-finger dexterous hand. The stock parallel gripper is replaced by a four-finger hand driven from a single leader-arm servo, delivering synchronized four-finger grasping and extension through a simple, reliable, factory-assembled mechanism. Built on the Hugging Face LeRobot ecosystem, it supports leader-follower teleoperation, dual-view data collection and end-to-end imitation learning with ACT, SmolVLA, Pi0, Pi0.5 and GR00T N1.5 — the easiest starting point for moving from a gripper to a dexterous hand.

SO-ARM101 is an open-source 6-axis robotic arm deeply optimized from SO-ARM100. Revised cable routing and motor/gear pairings eliminate the joint cable-breakage issue and no longer restrict the range of motion of the joints, while supporting real-time leader-follower following and seamless compatibility with the Hugging Face LeRobot toolkit.
AmazingHand is an open-source, low-cost, fully 3D-printable 8-DOF robotic hand development kit. Its servos are housed entirely inside the hand body with a cable-free internal design, and each finger is driven by two joints, combining dexterity with natural inter-finger collaboration.
Every unit ships factory assembled, wired and calibrated, dispatched by SF Express with free shipping. Invoices are available on request.
Key Advantages
-
Four-Finger Dexterous Hand with 8 Degrees of Freedom
AmazingHand provides four fingers (thumb, index, middle and ring), two articulated phalanges per finger and 8 degrees of freedom in total. A parallel linkage mechanism lets the fingers work together for a more natural grasp, while every servo sits inside the hand body with no external cabling for a compact, clean build.
-
Single-Servo Linkage Drives All Four Fingers
The No.6 servo (STS3215) on the leader arm drives all eight SCS0009 bus servos inside the hand through range mapping, so a single motion produces synchronized four-finger grasping (closed fist) or extension (open palm). Simple mechanics, reliable control, and no complex hand-side programming.
-
End-to-End Imitation Learning with ACT, SmolVLA, Pi0, Pi0.5 and GR00T N1.5
Run leader-follower teleoperation to record demonstration data, then train an imitation learning policy in a single pass. A small dataset is enough for the follower arm to complete preset grasping tasks autonomously, and the whole loop can be closed without writing code from scratch.
-
Dual-View Data Collection
An overhead bracket camera covers the entire workspace from above to establish the spatial position and orientation of target objects, while a desk-stand side-view camera streams workspace context in real time. Together they keep manipulation precise, respond quickly to changes in the scene, and prevent drift or stalling.
-
Factory Assembled, Ready to Use Out of the Box
Each unit ships assembled, wired and calibrated — connect power and USB and the platform is ready for teleoperation and data collection. Camera options include an 86° auto-focus 30FPS module and a 100° wide-angle fixed-focus 60FPS module, USB driver-free and plug-and-play.
-
Seamless Hugging Face LeRobot Integration
Reuse LeRobot's pretrained models, datasets and algorithm libraries directly, share code and experience with a global developer community, and enter embodied AI without rebuilding the toolchain yourself.
Hardware Overview


Available Versions (Select based on your end effector needs):
|
Version |
End Effector |
Hand Control |
Suitable For |
|
Pro Version |
TPU flexible gripper |
Independent servo control |
Users who need the standard SO-ARM101 two-finger gripper |
|
Dexterous Hand Version |
AmazingHand four-finger dexterous hand |
Leader arm No.6 servo range-mapped to drive 8 bus servos in unison |
Users exploring dexterous grasping and end-to-end imitation learning |
Grasp method: the Pro Version uses two-finger pinching, while the Dexterous Hand Version uses four-finger grasping and extension. Independent per-finger control is not supported in the current version and is on the development roadmap.
Compatible Devices:
Raspberry Pi / D-Robotics RDK / NVIDIA Jetson series controllers, plus Windows and Linux host PCs over USB serial. Fully compatible with the LeRobot SO-ARM101 and AmazingHand open-source projects, and supports most serial bus servos on the market.
3-Step Easy Setup:
-
Connect the servo driver board to your Raspberry Pi, RDK or Jetson controller with the supplied cable, then power the leader arm (DC5521 5V6A) and the follower arm (DC5521 12V5A).
-
Power on and connect over USB serial. The arm and hand ship assembled, wired and calibrated — no mechanical assembly or servo ID setup is required.
-
Follow the provided LeRobot tutorials to teleoperate the follower arm, collect dual-view datasets and train your imitation learning policy.
Technical Specifications
Dexterous Hand (AmazingHand)
|
Finger Span |
195mm ~ 101mm |
|
Degrees of Freedom |
8 DOF (driven by 8 bus servos) |
|
Single-Finger Load Capacity |
0.2kg (maximum 0.5kg with all four fingers in a full grip) |
|
Number of Fingers |
4 (thumb, index, middle, ring) |
|
Phalanges per Finger |
2 |
|
Hand Weight |
0.416kg |
|
Finger Bending Range |
First phalanx 0~86°, second phalanx 0~80° |
|
Finger Side-Roll Angle |
Thumb 20°, other three fingers -20°~20° |
|
Supply Voltage |
6V DC |
|
Control Method |
Driven by the leader arm No.6 servo — synchronized four-finger grasp / extension |
|
Power |
Maximum 48W, rated 4.8W |
Robotic Arm (SO-ARM101)
|
Product Material |
Bambu PLA+ |
|
Product Dimensions |
Leader arm: 111 x 239 x 525mm Follower arm: 111 x 173 x 532mm |
|
Product Weight |
Leader arm: approx. 680g Follower arm: approx. 690g |
|
Servo Driver Board |
JUXI Bus Servo Adapter |
|
Camera |
2MP HD auto-focus 30FPS camera (1080P) 2MP HD fixed-focus 60FPS camera (1080P) |
|
Power Supply |
DC5521 5V6A (Leader arm) / DC5521 12V5A (Follower arm) |
|
Operating System |
Windows / Linux |
|
Control Interface |
USB serial communication |
|
Programming Language |
Python |
Servo Configuration
|
Position |
Servo Model |
Gear Ratio |
Quantity |
|
Leader arm — No.2 joint (7.4V) |
STS3215-C001 |
1:345 |
1 |
|
Leader arm — No.1 and No.3 joints (7.4V) |
STS3215-C044 |
1:191 |
2 |
|
Leader arm — No.4, No.5 joints and No.6 gripper / hand (7.4V) |
STS3215-C046 |
1:147 |
3 |
|
Follower arm — all joints, Pro Version (12V) |
STS3215-C018 |
1:345 |
6 |
|
Follower arm — arm joints, Dexterous Hand Version (12V) |
STS3215-C018 |
1:345 |
5 |
|
AmazingHand dexterous hand (6V) |
SCS0009-C001 |
— |
8 |
SCS0009 Bus Servo (Dexterous Hand)
|
Servo Model |
Feetech SCS0009-C001 (2.3kg single-axis serial bus servo) |
|
Rotation Speed |
0.07sec/60° (143RPM) @6V |
|
Stall Torque |
2.3kg.cm @6V |
|
Servo Precision |
0.293° (300/1024) |
|
Sensor & Range |
Potentiometer sensor, 300° controllable, supports both angle-controlled servo mode and continuous-rotation wheel mode |
|
Protection |
Voltage protection, stall protection, over-temperature protection |
|
Data Readback |
Supported — temperature, speed, voltage and position feedback |
|
Deployment |
Two SCS0009 servos per finger, delivering fast coordinated response and smooth finger motion |
STS3215 Bus Servo (Robotic Arm)
|
Parameter |
STS3215-C001 |
STS3215-C018 |
|
Rotation Speed |
0.192sec/60° (52RPM) @7.4V |
0.222sec/60° (45RPM) @12V |
|
Stall Torque |
19.5kg.cm @7.4V |
30kg.cm @12V |
|
Servo Precision |
0.088° |
0.088° |
|
Sensor & Range |
12-bit high-precision magnetic encoder, 360° controllable |
12-bit high-precision magnetic encoder, 360° controllable |
|
Protection |
Voltage protection, stall protection, over-temperature protection |
Voltage protection, stall protection, over-temperature protection |
|
Data Readback |
Supported — angle, temperature, voltage and position feedback |
Supported — angle, temperature, voltage and position feedback |
The STS3215 integrates two high-quality magnetic encoder motors with millisecond-level coordinated response and multiple operating modes, keeping every arm motion smooth and precise.
JUXI Bus Servo Adapter (Driver Board)
|
Power Input |
7~12V |
|
Power Connector |
DC5521 |
|
Servo Interface |
PH2.0 bus servo interface |
|
Communication Interface |
USB Type-C |
|
Mounting Hole Spacing |
37.00 x 28.00mm |
|
Mounting Hole Diameter |
2.5mm |
|
Product Dimensions |
42.00 x 33.00mm |
|
Product Weight |
15g |
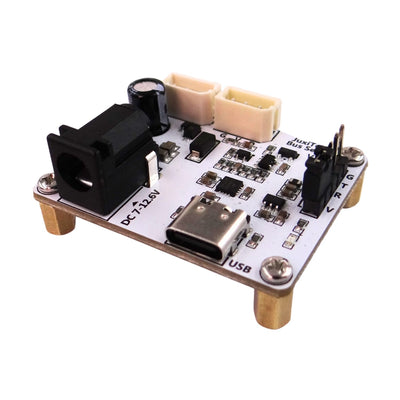
The board features a compact plug-and-play design with a TVS voltage-regulation protection module to prevent high-voltage breakdown. A single cable connects it to Raspberry Pi, D-Robotics RDK or NVIDIA Jetson controllers for real-time motor control and encoder data feedback. It supports the LeRobot SO-ARM101 arm, the AmazingHand dexterous hand and most serial bus servos on the market.
Camera Module (Optional)
|
Resolution |
1080P, 2MP |
|
Available Options |
86° auto-focus 30FPS camera / 100° wide-angle fixed-focus 60FPS camera |
|
Interface |
USB, driver-free and plug-and-play |
|
Mount Options |
Side-view or top-view camera mount kit |
Applications
-
University research — teaching labs and research projects in robotics, artificial intelligence and automation, particularly dexterous grasping and imitation learning.
-
Developers and makers — algorithm development, prototype validation, secondary development of the dexterous hand, and robotics competitions.
-
Educational institutions — an ideal teaching aid for advanced courses in AI programming and robot vision.
-
Enthusiasts — build a desktop robot that puts real AI techniques to work and grasps with a human-like hand.
Open Source & Ecosystem
This product is built on the open-source LeRobot SO-ARM101 project and the AmazingHand project. The SO-ARM101 & AmazingHand platform connects seamlessly to the Hugging Face community: LeRobot's pretrained models, datasets and algorithm libraries can be reused directly, and code and experience can be shared with developers worldwide — lowering the technical barrier to entering embodied AI.
-
Source code is released under the Apache License 2.0.
-
Mechanical design files are released under the CC BY 4.0 license.
Technical Support
A complete, step-by-step replication tutorial covers the full workflow, so even users with no programming background can reproduce and deploy the platform without barriers. Search for "JuxiTechnology" on GitHub or Gitee to view the materials, or contact our support team if you run into any issues.
-
Full assembly, wiring and calibration reference.
-
Leader-follower teleoperation setup and servo ID configuration.
-
Dual-view camera mounting and LeRobot dataset collection guide.
-
Imitation learning training and deployment walkthroughs (ACT, SmolVLA, Pi0, Pi0.5, GR00T N1.5).
For detailed technical documentation on software setup and code implementation, please refer to our official Wiki:
Access Here (SO-ARM101 Robotic Arm Tutorial)
Access Here (AmazingHand Dexterous Hand Tutorial)
Community technical support is also available to help you accelerate project implementation.
Package Options
|
Package |
AmazingHand (Finished) |
SO-ARM101 Pro Version |
SO-ARM101 Dexterous Hand Kit |
Dexterous Hand Kit (Dual Camera) |
|
3D Printed Parts |
✓ |
✓ |
✓ |
✓ |
|
AmazingHand Dexterous Hand |
✓ |
— |
✓ |
✓ |
|
Scene Camera |
— |
— |
— |
✓ |
|
Dual-View Data Collection |
— |
— |
— |
✓ |
|
Leader-Follower Teleoperation |
— |
✓ |
✓ |
✓ |
|
End-to-End Imitation Learning |
✓ |
✓ |
✓ |
✓ |
Part List
SO-ARM101 Dexterous Hand Kit:
-
1 x Leader arm (assembled) — 1 x STS3215-C001 (7.4V, 1:345), 2 x STS3215-C044 (7.4V, 1:191), 3 x STS3215-C046 (7.4V, 1:147)
-
1 x Follower arm (assembled) — 5 x STS3215-C018 (12V, 1:345)
-
1 x AmazingHand four-finger dexterous hand (assembled) — 8 x SCS0009-C001 (6V) bus servos
-
2 x JUXI Bus Servo Adapter (servo driver board)
-
1 x DC5521 5V6A power supply cable (leader arm)
-
1 x DC5521 12V5A power supply cable (follower arm)
-
2 x USB Type-C cable
-
4 x Fixing clip
-
1 x USB hub
SO-ARM101 Dexterous Hand Kit (Dual Camera):
Everything in the SO-ARM101 Dexterous Hand Kit, plus:
-
1 x Overhead (top-view) camera mount kit with 2MP 1080P camera module
-
1 x Desk-stand side-view camera kit with 2MP 1080P camera module
SO-ARM101 Pro (TPU Gripper):
-
1 x Leader arm (assembled) — 1 x STS3215-C001 (7.4V, 1:345), 2 x STS3215-C044 (7.4V, 1:191), 3 x STS3215-C046 (7.4V, 1:147)
-
1 x Follower arm (assembled) with TPU flexible gripper — 6 x STS3215-C018 (12V, 1:345)
-
2 x JUXI Bus Servo Adapter (servo driver board)
-
1 x DC5521 5V6A power supply cable (leader arm)
-
1 x DC5521 12V5A power supply cable (follower arm)
-
2 x USB Type-C cable
-
4 x Fixing clip
-
1 x USB hub
Amazing Hand(Right Hand):
-
1 x AmazingHand four-finger dexterous hand, fully assembled with 8 x SCS0009-C001 (6V) bus servos
-
1 x JUXI Bus Servo Adapter (servo driver board)
-
1 x Interconnect cable
常見問題
什麼是 SO-ARM101 & AmazingHand Open Source Dexterous Hand Robotic Arm?
在哪裡可以找到 SO-ARM101 & AmazingHand Open Source Dexterous Hand Robotic Arm 的技術文檔和開源文件?
SO-ARM101 & AmazingHand Open Source Dexterous Hand Robotic Arm 相容哪些平台和框架?
如何取得 SO-ARM101 & AmazingHand Open Source Dexterous Hand Robotic Arm 的技術支援?
No Video
您可能也會喜歡這些內容

兩自由度伺服雲台

3D RealSense 深度攝影機

四合一 KVM 多電腦切換器集線器 | TTL 序列藍牙擴展塢

4K高畫質HDMI影像擷取卡


79° IMX219 CSI 相機

AHRS姿態航向感測器IMU模組,用於機器人導航

AI 語音辨識模組 — 關鍵字喚醒、雙語語音、110+ 命令

用於研究的 AmazingHand 開源仿生機械手

匯流排伺服驅動板


免驅動 USB 2.0 聲卡,帶內置麥克風,適用於 AI 語音互動
閱讀 wiki.juxitech.com 上的技術文件、原理圖和研究論文。